Articles in this Volume

Research Article Open Access
A Comparative Study of BFS and Left-Hand Wall-Following Algorithms for Maze Solving in OCaml
This paper aims to investigate and solve maze-solving problems by implementing the Breadth-First Search (BFS) algorithm and the Left-Hand Wall-Following algorithm, providing references for maze navigation of small embedded robots. In this study, the OCaml programming language is adopted. This paper implements both the BFS and Left-Hand Wall-Following algorithms to solve three mazes of different sizes (30×28, 30×17, 30×16). The total moving steps and the shortest valid paths are recorded. The time and space complexity of the two algorithms are calculated, and comparative tables are generated for analysis. Experiments show that the Left-Hand Wall-Following algorithm has a constant space complexity of O(1) with stable memory consumption. However, its generated path length can reach 2.5 to 10 times the theoretical shortest path, and it is only applicable to simple mazes. In contrast, BFS can stably output globally optimal paths and adapt to all types of complex mazes, yet its memory overhead grows linearly with maze size. The two algorithms fit distinct application scenarios and can be selected flexibly according to equipment memory constraints and requirements for optimal paths.
Show more
Read Article PDF
Cite
Research Article Open Access
Robot Path Planning in Complex Environments: Methods, Challenges and Future Directions
Robot path planning is a fundamental problem in robotics enabling autonomous robots to navigate safely, efficiently and naturally from a start position to a target position. In real robotic systems, path planning is not only about finding a collision-free path, but also about generating motions that satisfy the robot's physical, sensory, and task constraints. In this essay, the main robot path planning methods, including graph search, artificial potential field methods, sampling-based planning, local obstacle avoidance, and trajectory optimization are reviewed. Their respective strengths, limitations, and applicable scenarios are examined, with particular attention to how these approaches address issues such as computational complexity, environmental structure, and real-time responsiveness. It also addresses present day issues such as uncertainty, dynamic environments, computational efficiency and physical feasibility, emphasizing that no single method is sufficient for all robotic applications. Practical systems increasingly rely on hierarchical integration to balance global navigation with local reactivity. Finally, the essay argues that the future of robot path planning will be dominated by hybrid systems that combine global planning, local replanning, optimization, and learning-based prediction, enabling robots to operate more safely, intelligently, and adaptively in complex real-world environments.
Show more
Read Article PDF
Cite
Research Article Open Access
The Chromatic Index of Asymmetric Pendant Helm Graphs — A Constructive Proof of the Class 1 Property for a Generalized Helm Family
Article thumbnail
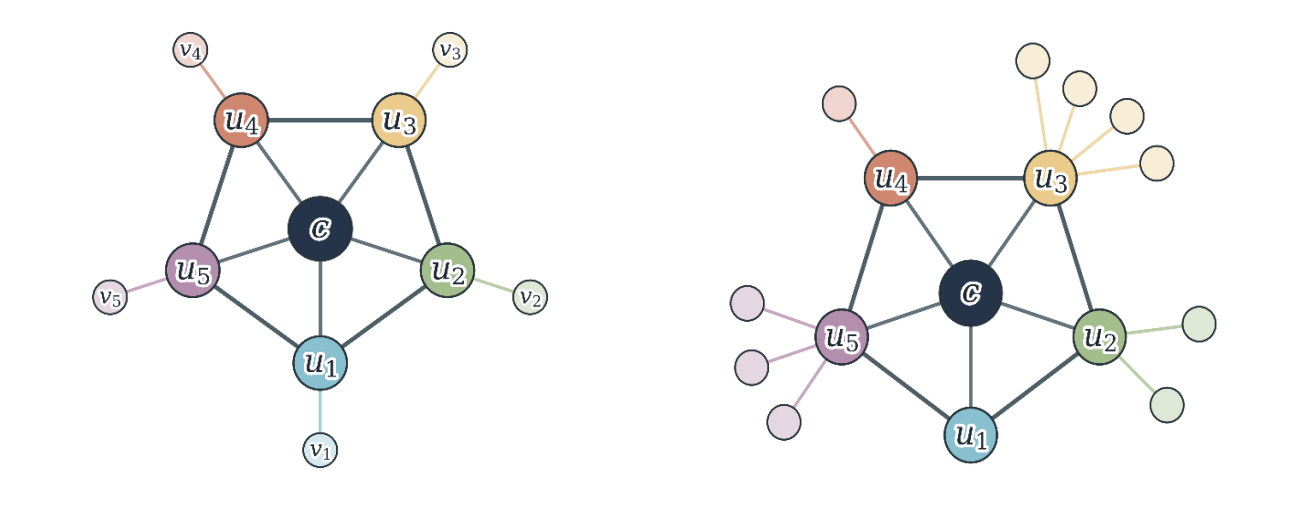
The classical helm graph is obtained from a wheel graph by attaching a single pendant edge to each vertex on its outer cycle. While the chromatic index of the classical helm graph has been determined previously, that for nonuniform pendant extensions remains unexplored. In this paper, we introduce the asymmetric pendant helm graph, a natural generalization in which each outer vertex may carry an arbitrary number of pendant edges. We prove that every asymmetric pendant helm graph is Class 1, with the chromatic index equal to the maximum degree. The proof is constructive and yields an optimal linear-time edge coloring algorithm. As special cases, the result recovers known conclusions for classical helm graphs, wheel graphs, and uniform multi-pendant helm graphs. We further validate the proposed construction computationally using ten representative graph instances.
Show more
Read Article PDF
Cite
Research Article Open Access
Implementation and Comparison of Maze Solving Algorithms in OCaml
Article thumbnail
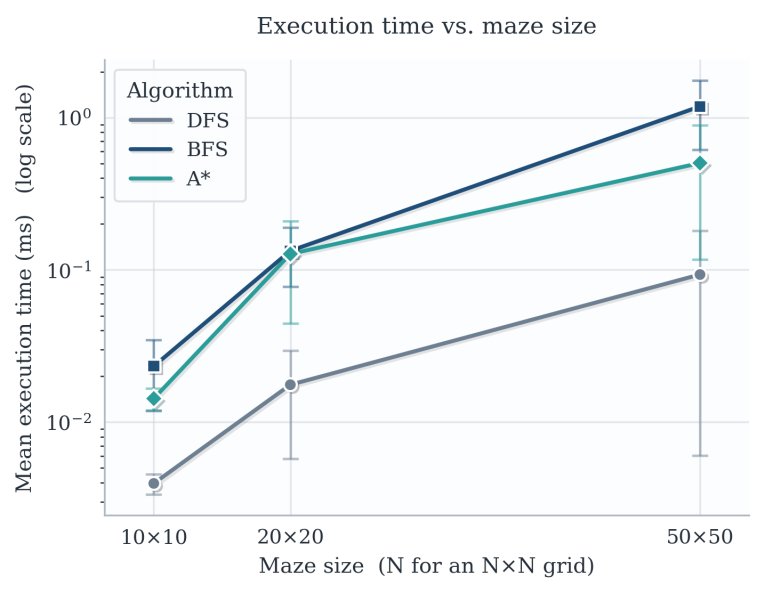
With the continuous development and application needs of robots, games and intelligent navigation, maze-solving algorithms have also begun to be researched in relation to traditional graph-search algorithms. The three maze-solving algorithms and their corresponding results in this paper are DFS, BFS and A*, and they are all based on graph-search methods for 2D-grid mazes. A* is based on the Manhattan distance. Experiments are carried out on the three types of mazes (sparse, dense and complex) and the three scales (10x10, 20x20 and 50x50), and the main indicators are execution time, path length, visited nodes and scalability. BFS and A* both return the shortest path; however, A* has visited fewer nodes than BFS. For example, 419 vs. 1480 in the 50x50 maze; DFS can find the maze in the shortest time but has a longer path. As OCaml has pattern matching and recursion, it can be used to implement the above search algorithm.
Show more
Read Article PDF
Cite
Research Article Open Access
Logistics Systems in Industrial Engineering: An Operations Research Perspective
Modern logistics systems require coordinated decisions across production, inventory, warehousing, transportation, and supply networks. This narrative literature review examines these systems from an operations research (OR) perspective within industrial engineering. It summarizes the role of deterministic optimization, stochastic models, simulation, heuristics, and learning-assisted methods. It then reviews their applications in supply chain network design, inventory management, production scheduling, and warehouse optimization. The review shows that OR is most valuable when logistics is treated as an integrated system rather than a set of isolated activities. Traditional models remain essential for structured and stable problems, while uncertain and dynamic environments increasingly require adaptive, data-supported approaches. Future progress will depend on real-time model updating, multi-objective decision-making, and digital twins, as well as the integration of intelligent methods with explicit OR constraints and system-level objectives.
Show more
Read Article PDF
Cite
Research Article Open Access
SEIR-Based Modeling of COVID-19: Comparative Evaluation of Parameter and Equation Choices
Article thumbnail
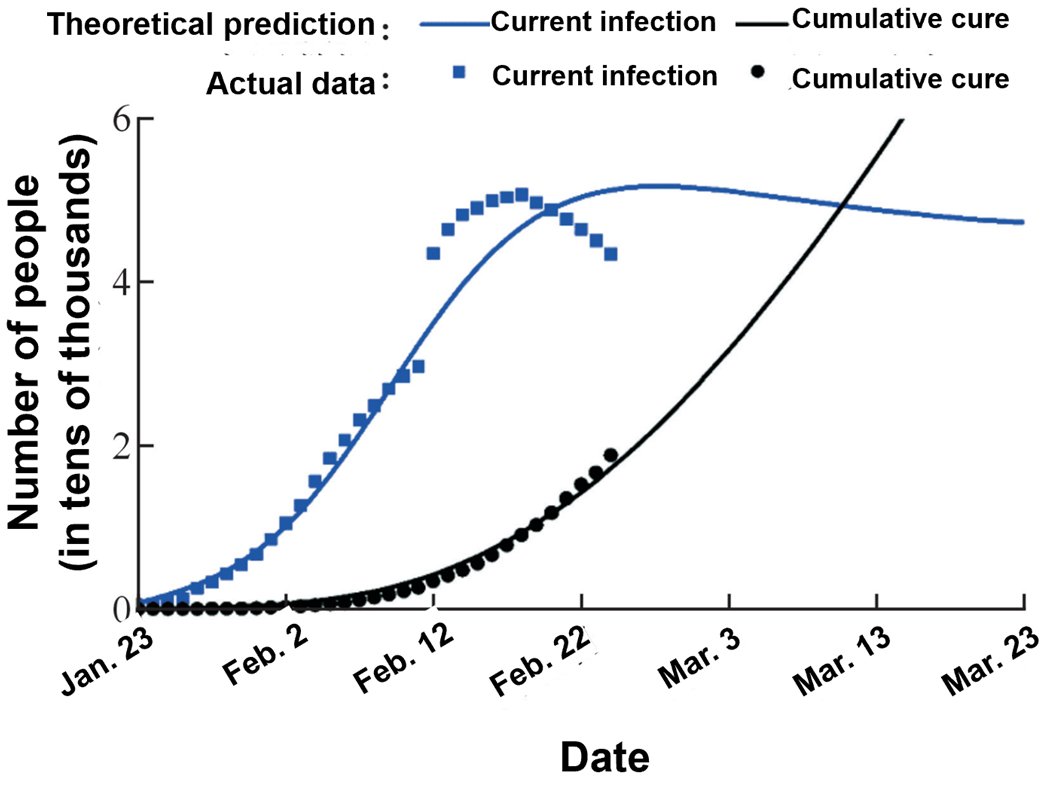
This article compares the accuracy of susceptible‑exposed‑infected‑recovered (SEIR) model and two improved models in terms of case number fitting and peak prediction during the early stage of the epidemic in the same province (from January 2020 to March 2020), examining whether there are any issues with the models. The paper uses some models and data as examples to analyze the advantages and disadvantages of different models. That's an important task because models may not fit reality satisfactorily or need more time to calculate if the models are not good enough. In some cases, researchers even need to give up the models. In the research, the author tidied up some papers that told people how to use SEIR models and their variants to analyze coronavirus disease 2019 (COVID‑19), and the author found that in most cases, people need to decrease the number of parameters and use the real parameters. There are also a few exceptions. The scholars employed some special algorithms or other mathematical tools to enhance the accuracy of the model and effectively avoid a series of problems caused by excessive parameters and variables. However, according to the author's observation, the number of such articles is relatively small and requires a very high level of mathematical knowledge. Most articles still use fewer variables and employ actual parameters.
Show more
Read Article PDF
Cite
Research Article Open Access
Mathematical Modeling Strategies and Challenges for Inferring Football Match Results
This paper reviews mathematical and computational prediction models which forecast football match outcomes. It also summarizes common models, data inputs, and key challenges. Based on a survey of statistical methods including Poisson and Elo, machine learning, neural network, and deep-learning approaches, the review compares how different techniques use match-level, team-level, player-level and external features. It specifically shows which inputs tend to improve prediction, such as in-game statistics and player information, as well, and it explains typical evaluation practices and performance limits. Major obstacles include noisy or incomplete data, the inherent randomness of sport, class imbalance especially matches with draw outcomes, and the computational cost of complex models. The paper also points out practical directions to improve reliability, including combining diverse datasets, and focusing on model interpretability so coaches and analysts can trust outputs and apply them to improve team performances. Overall, although many methods show a good future potential, significant doubts still remain. In future works, the priority should be on gathering more reliable data and improving how to explain the models.
Show more
Read Article PDF
Cite
Research Article Open Access
Monte Carlo Simulation for Estimating π: Algorithm Principle and Error Analysis
Monte Carlo simulation is a stochastic numerical method that approximates solutions to mathematical problems via repeated random sampling. Owing to its conceptual simplicity and broad applicability, it has become a foundational computational tool across physics, finance, engineering, and data science. This paper examines the algorithmic principle of Monte Carlo π estimation and systematically analyzes factors governing simulation accuracy. A Python-based numerical simulation is implemented: uniformly distributed random points are generated within a unit square, and the value of π is estimated by counting points falling inside the inscribed quarter circle. Experiments with varying sample sizes are conducted to assess their impacts on estimation accuracy and convergence behavior, and the influence of pseudo-random number generation on simulation outcomes is also discussed. The results confirm that estimation stability improves with increasing sample size, and the simulation error decays approximately at a rate proportional to the inverse square root of the sample size. This study elucidates the mathematical fundamentals underlying Monte Carlo simulation and offers an intuitive case for understanding the properties, strengths, and limitations of stochastic numerical methods. The findings deepen understanding of the relationship between sample size and simulation accuracy, and provide theoretical and practical support for extending Monte Carlo methods to more complex numerical simulation and uncertainty analysis tasks.
Show more
Read Article PDF
Cite
Research Article Open Access
Driving Factors of Monthly PM2.5 Concentrations in Shanghai (2020–2024): Panel Data Estimation
Ambient fine particulate matter (PM2.5) continues to pose serious risks to public health, yet the interaction between weather conditions and human-induced emissions in coastal megacities has not been fully captured by existing studies. To fill this gap, the present work develops an integrated econometric framework for quantifying the main determinants of Shanghai's PM2.5 levels over the 2020–2024 period. A balanced monthly panel of 60 observations was used; both fixed-effects and random-effects regressions were applied, and the Hausman test was used to select the model, while OLS results were also compared for consistency; the results showed that weather factors like wind speed and rainfall are the main short-run drivers; specifically, a 1 m/s increase in wind speed reduces PM2.5 by 2.45 μg/m³, and a 1 mm rise in rainfall leads to a 0.05 μg/m³ decline; as for human-caused sources, the number of vehicles and industrial production stand out as the main positive contributors; an increase of 10,000 vehicles is associated with a 1.2 μg/m³ increase in PM2.5; on the other hand, when urban green coverage expands by 1%, PM2.5 goes down by 0.85 μg/m³; the Hausman test produced a p-value of 0.03, which means the fixed-effects model is chosen, and this points to the need to account for unobserved factors that stay constant over time; these findings indicate that nature and human actions are both crucial, and the study lends empirical backing to policies such as promoting cleaner industrial processes, regulating traffic, and expanding urban green spaces.
Show more
Read Article PDF
Cite